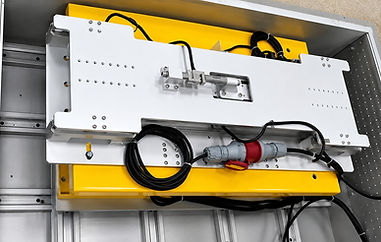
What happens to the complete vehicle when the steering system fails or locks up at high speed? Testing that on a road puts the driver at serious risk. Skipping the test leaves the OEM without an answer. KTL's Te.Sense Bonito steering force emulator works with your hub-coupled dynamometer to reproduce steering loads and failure scenarios on a complete, running vehicle, under controlled laboratory conditions.
As intelligent and automated vehicles increasingly adopt steer-by-wire and rear-wheel steering systems, they bring higher functional-safety risks. Hazardous conditions such as loss of steering control at high speed must be fully validated in the laboratory before road testing begins, and the steering force emulator is the key equipment for doing exactly that.
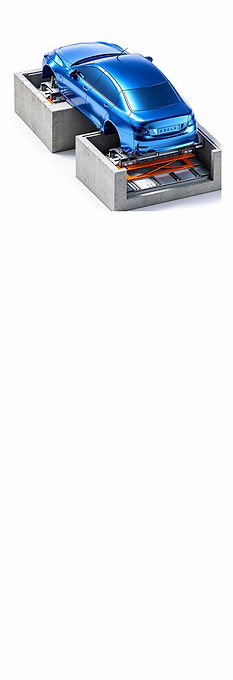
Built for steering functional-safety validation: Te.Sense Bonito supports steering functional-safety test and validation requirements under ISO 26262 (functional safety), ISO 19725 (steer-by-wire systems – system safety guidelines), ISO 21448 (SOTIF) and GB 17675-2025. The equipment supports both floor-mounted and pit-mounted installation.

Te.Sense Bonito
High-performance, real-time steering rack load simulator delivering up to 20 kN (4,500 lb) of rack force at speeds above 2 m/s. Fully compatible with hub-coupled and powertrain dynos, test benches, and Hardware-in-the-Loop (HIL) / Vehicle-in-the-Loop (ViL) simulation environments, with chassis dyno integration on request. Proven in installed complete-vehicle projects.
Features
-
Functional-safety validation for steer-by-wire and rear-wheel steering systems, supporting ISO 26262, ISO 19725, ISO 21448 (SOTIF) and GB 17675-2025 test requirements
-
Validates ADAS/AD lateral control functions such as Lane Keeping Assist (LKA) with realistic steering rack force feedback
-
Tests electric power steering (EPS), steer-by-wire and rear-wheel steering systems on the complete vehicle
-
Reproduces steering failures, lock-ups and dynamic steering loads on a complete, running vehicle
-
Faster dynamic response and more accurate force tracking than conventional electric-cylinder systems
-
Compatible with hub dynos from AVL, HORIBA, FEV, Rotronic and others
-
Supports floating-floor and fixed steel-platform hub dyno installations; custom solutions for traditional chassis dynos
-
Electro-magnetic actuation that simulates real-time steering rack loads for HIL and VIL testing
-
Compatible with axle-coupled dynamometers, steer-by-wire systems, etc.
-
Enables human steering system interactions during bench and lab tests
-
Can be mounted to chassis, test bench; Supports both above-ground and underground arrangements
-
Compact design eliminates interference with chassis dynos and other systems
-
Low latency response with zero backlash
-
High mechanical stiffness for stability, accuracy and long service life
-
Robust force control for reduced sensitivity to micro-vibrations during dyno operation
-
Can be configured to suit most HIL data communication protocols and simulation environments
Technical Specifications
Te.Sense Bonito steering emulator systems are the perfect solution for special steering system characterizations that support ADAS developments and other vehicle control studies. Sometimes real-time human interactions (control and feedback) are necessary in conjunction with powertrain dyno and bench tests, and virtual test driving scenarios. Te.Sense Bonito has been designed for exactly such cases.
With Te.Sense Bonito, simulated road loads are applied through a low-maintenance, compact, electro-magnetic servo linear motion mechanism, offering high speed, low latency, and zero backlash during directional changes. It's a must-have tool for passive and active steering system tuning in lab environments.
These turn-key devices are fully compatible with HIL and VIL ecosystems, and can be easily integrated as supplemental devices to increase test and simulation capabilities. Te.Sense Bonito can be mounted to vehicle chassis or to test benches. It can accommodate front and rear steering configurations, and it can be configured for both above-ground and underground installations when used in conjunction with powertrain or hub-coupled dynos.
Proven in Real Projects
This isn't a concept. KTL steering force emulators are already installed for complete-vehicle testing with hub-coupled dynos. Two projects are in operation, one has completed customer acceptance, and a third project is starting soon. Contact us to see photos and video of the system running in a customer lab.
Simulation and Automation
KTL develops the communication interface and provides on-site commissioning support for major vehicle dynamics and ADAS/AD simulation platforms, including CarSim, VTD, IPG, SCANeR and PreScan. Add KTL steering and pedal driving robots to automate test scenarios for long-duration or 24/7 operation. This is ideal for ADAS and autonomous-driving validation and for high-mileage pre-production vehicle testing.